
2026-10-22 東北大学
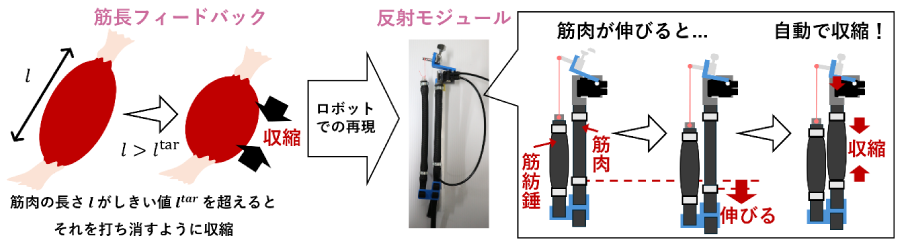
図1. 提案した反射モジュール。(左)筋長フィードバックの概念図。(右)反射モジュールの写真と動作原理。
<関連情報>
- https://www.tohoku.ac.jp/japanese/2026/10/press20261022-02-reflexive.html
- https://advanced.onlinelibrary.wiley.com/doi/10.1002/aisy.70590
純粋に機械的な筋肉長フィードバックにより、筋骨格ロボットにおける身体化された反射制御が可能になる Purely Mechanical Muscle Length Feedback Enables Embodied Reflexive Control in Musculoskeletal Robots
Shunsuke Koseki, Mitsuhiro Hayashibe, Dai Owaki
Advanced Intelligent Systems Published: 21 October 2026
DOI:https://doi.org/10.1002/aisy.70590
Abstract
Reflexes are a fundamental principle of biological movement; however, their application in musculoskeletal robots has been limited due to reliance on complex electronic sensing and control systems. This study presents the first implementation of the muscle length feedback reflex and establishes a minimal sensorimotor unit based on mechanical intelligence. Specifically, the proposed reflex module integrates sensing, computation, and actuation within its physical architecture, enabling autonomous contraction when muscle length exceeds a threshold, entirely without electronic components. Additionally, a muscle spindle-inspired mechanism allows for adaptive modulation of this threshold. When incorporated into musculoskeletal robots, the module reproduced the patellar tendon reflex. Furthermore, by integrating this mechanical reflex with high-level phase-dependent threshold modulation control, bipedal locomotion was generated as an emergent behavior. These findings demonstrate that essential local sensorimotor control can be physically realized within mechanical systems, providing a minimal, robust, and scalable design principle for musculoskeletal robotics and advancing embodied intelligence beyond traditional control architectures.