2026-10-13 中国科学院(CAS)
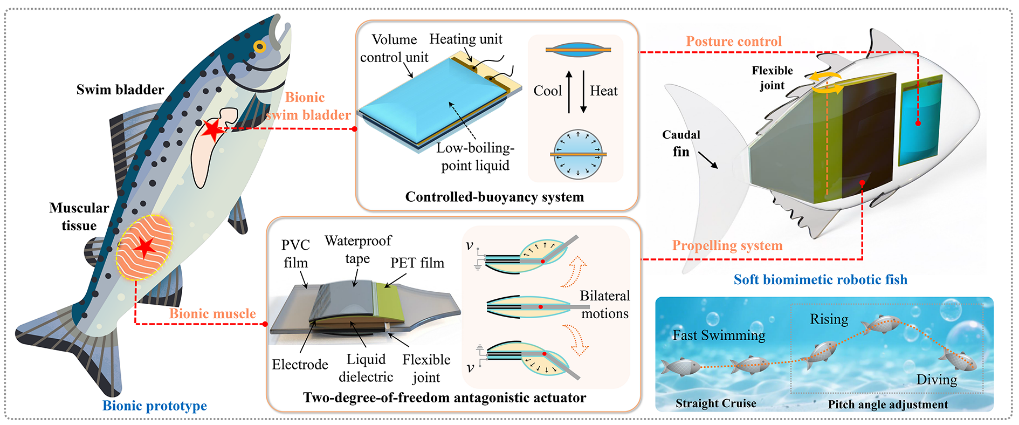
Biomimetic design and locomotion mechanism of the soft robotic fish (Image by SIA)
<関連情報>
- https://english.cas.cn/newsroom/research-news/202610/t20261010_1201860.shtml
- https://ieeexplore.ieee.org/document/11720228
電気油圧駆動式高速生体模倣ソフトロボット魚(柔軟な3次元機動性を備えた) Electrohydraulic Actuated High-Speed Biomimetic Soft Robotic Fish With Flexible 3D Maneuverability
Yiwei Zhang; Chuang Zhang; Hengshen Qin; Lianchao Yang; Qi Zhang; Fei Nie,…
IEEE/ASME Transactions on Mechatronics Published:05 October 2026
DOI:https://doi.org/10.1109/TMECH.2026.3732033
Abstract
Natural fishes exhibit remarkable propulsion and flexible three-dimensional (3D) maneuverability, inspiring research on biomimetic soft robotic fish. However, due to limitations in soft actuation performance and inadequate posture regulation, existing soft robotic fish still face challenges in achieving high-frequency rapid propulsion and multidimensional movement. In this article, we develop a soft robotic fish that achieves high swimming speed and flexible 3D motion by coupling electrohydraulic actuation with a buoyancy-based posture control unit. Specifically, a two-degree-of-freedom electrohydraulic actuator is designed and modeled to mimic antagonistic muscle contractions, enabling high-frequency oscillations for rapid propulsion. The experimental results showed that the soft robotic fish achieves a maximum speed of 2.13 BL/s and a low transport cost of 9.4 J/(kg·m), surpassing most previously reported soft robotic fish’s swimming performance. Moreover, by embedding a posture control system based on gas–liquid phase transition, the robotic fish can achieve a dynamic pitch angle ranging from -20° to 58°, thereby enabling versatile 3D trajectories such as ascent, descent, and spiral maneuvers. This article not only enhances swimming speed but also proposes a coupled actuation–posture cooperative control framework for advancing soft robotic fish from planar propulsion toward controllable 3D locomotion.